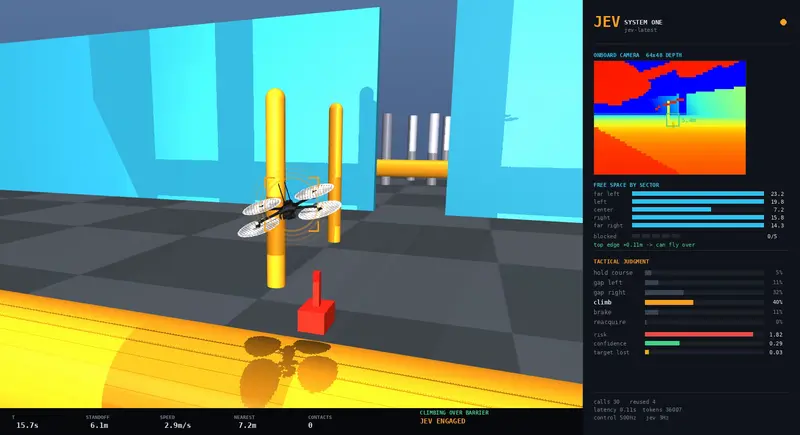
jev-drone
Camera-only autonomous drone simulated in MuJoCo with Jev in the control loop at 2.5 Hz.
 RomanSlackOpenjev-drone on github.com
164 starsCalls per flight ~110Decision rate ~2.5 Hz
ProjectReal-time control
Hardware projects need a controller that picks the next action from the current state: move the arm, steer the drone, switch the light. A decision model suits the choosing step. It takes the state as structured text and returns a typed choice with a confidence value, which a safe controller can bound and check before anything moves. The examples in this hub run on Jev and other decision models, and Laya appears in several. Most run in simulation. Examples include jev-drone by RomanSlack in MuJoCo, kxzk/typesafe-jev-drone-demo, and TarunTomar122/jev-askable-arm for a simulated Franka Panda arm. Smart-home entries are different: allenporter/home-assistant-typesafe and AboveColin/HA-Jev work with real Home Assistant setups. Before you copy one, check whether it has run on hardware at all, what hard limits sit outside the model, and what the device does when the model is unsure. Simulation results say little about a real device, so weigh each entry by how close it is to hardware. Safety limits belong in code you control.
15 entries
Showing 15 of 15
Camera-only autonomous drone simulated in MuJoCo with Jev in the control loop at 2.5 Hz.
RomanSlackOpenjev-drone on github.com164 starsCalls per flight ~110Decision rate ~2.5 Hz
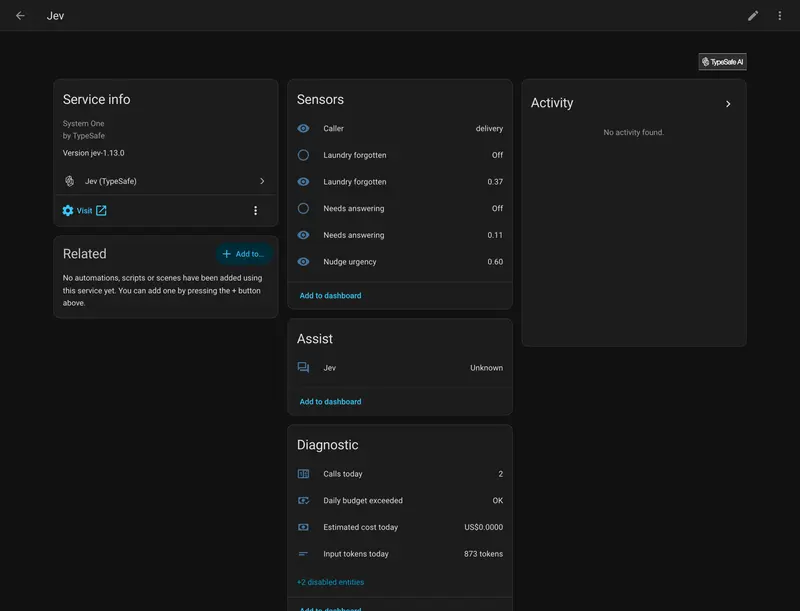
Unofficial Home Assistant integration that asks Jev questions about your house and turns each answer into an entity you can automate on. Questions in configuration.yaml become sensors, and four actions answer inside an automation and return a response variable.
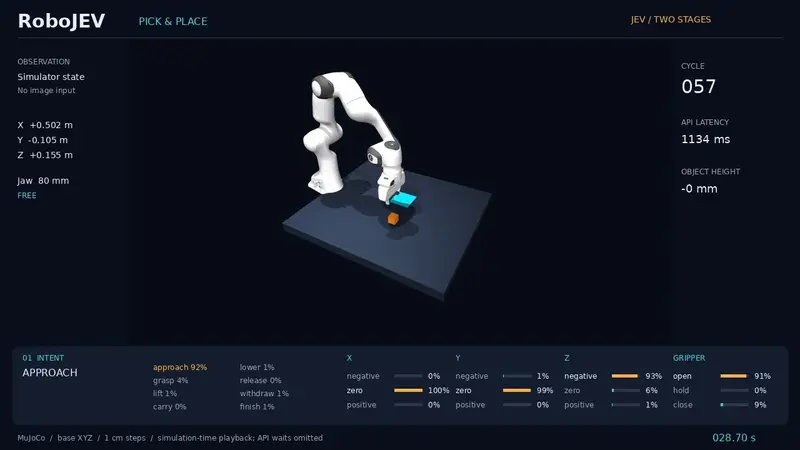
Two-stage Jev control of a Franka Panda arm in MuJoCo: Jev picks an intent from structured simulator state, then picks X/Y/Z motion and a gripper command, with a Cartesian controller executing the action against real physics.
Zero-shot robot tasks on a simulated Franka Panda in ManiSkill. Given a plain English goal and the scene, Jev picks one of about 30 hardcoded primitives per step and Python runs it, at roughly one second per pick. No training, demos or policy.
A fully local Home Assistant Assist conversation agent that scores registered intents and exposed entities with Laya in one forward pass, dispatching simple commands directly and escalating compound or low-confidence requests to a fallback LLM.
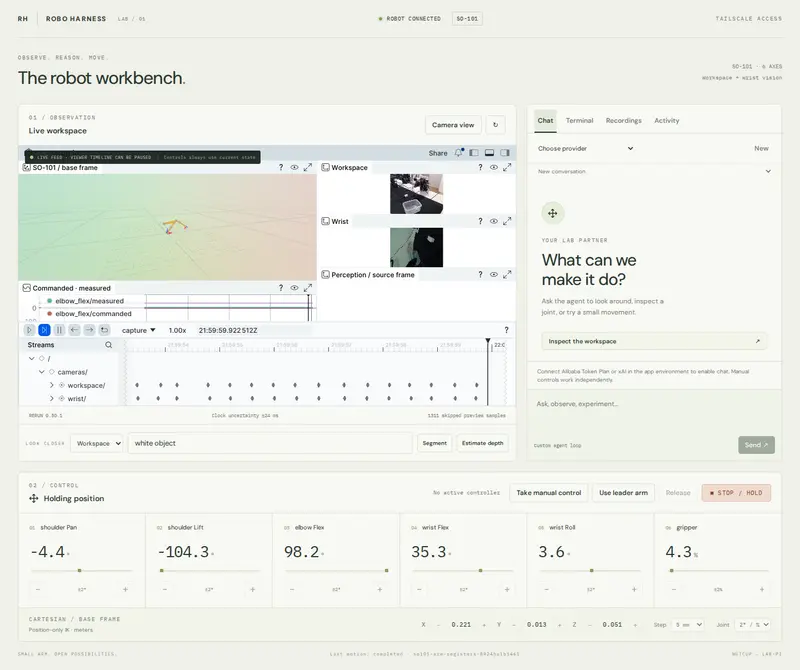
SO-101 robot-arm workbench with a Bun and Effect coordinator, a React workbench around Rerun, and a Python LeRobot hardware boundary. Its decision runner lets Jev, reached through the AI SDK evaluate API on Vercel AI Gateway, pick bounded joint steps under a spend cap, and chat and a decision run never move the arm at the same time.
A Home Assistant conversation agent where Jev classifies an utterance and either takes a fast-path light action or hands off to the Grok conversation agent, gated by confidence and yes/no thresholds.
Three.js drone simulation with a typed Python and FastAPI backend where jev-latest chooses each navigation action. The Choice distribution, Noul obstruction estimate, confidence, latency and the exact model input and output are visible beside the flight.
A simulated Swedish villa energy system compares Laya's live one-minute decisions against a naive charger, a tariff-aware controller and an optimal plan, cutting the naive controller's bill from 985 to 530 SEK.
A Home Assistant conversation integration that routes spoken or typed commands through Jev for intent classification and device control instead of a general-purpose LLM.
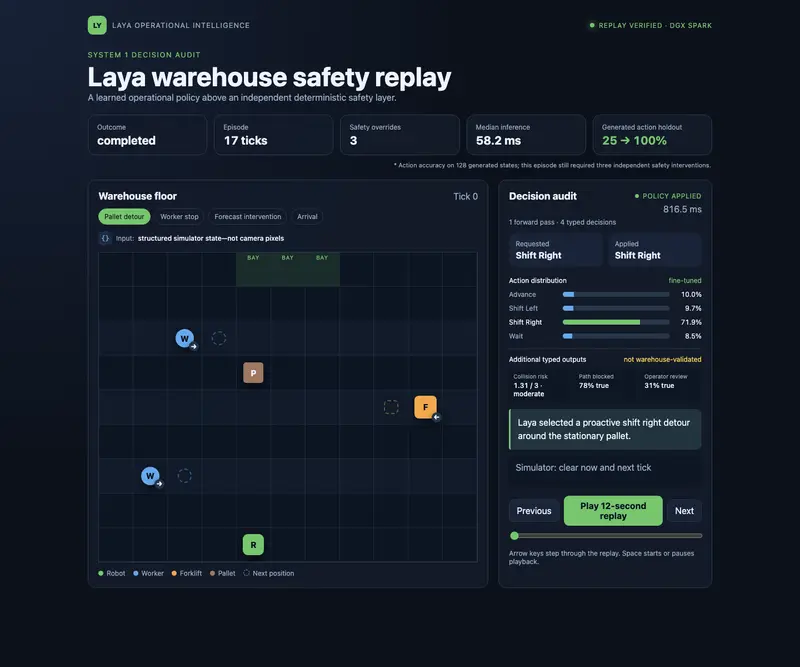
A replayable grid warehouse simulation where Laya answers action, collision_risk, path_blocked and needs_operator questions for a robot navigating toward a loading bay, layered above a deterministic safety shield it cannot override.
 senthilr-nvOpenLaya Warehouse Safety on github.com
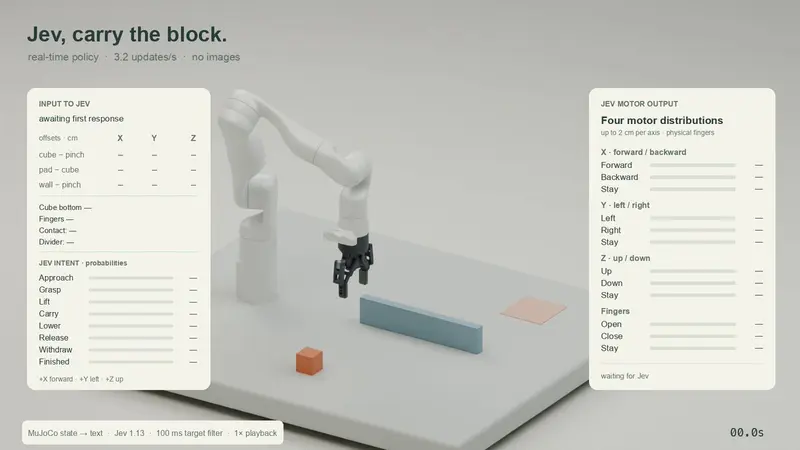
A video demo tests Jev as a real-time control policy for a robot arm in MuJoCo, splitting each update into two calls: one to decide the next action, another to decide how to move the arm and gripper. Jev receives simplified geometry and contact data as text rather than images.
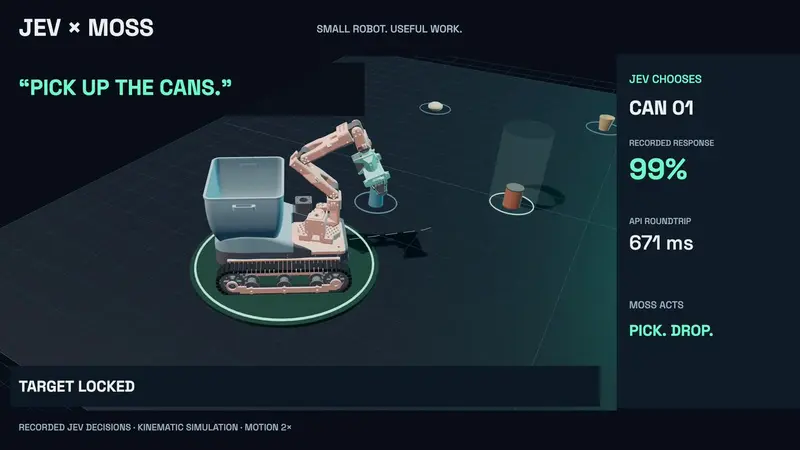
Jev picks the target for the MOSS litter-picking robot, for example switching from cans to bottles on a new instruction. In the newer v0.2 physics replays it also picks each arm action, and the page replays MOSS acting on Jev's real recorded decisions.
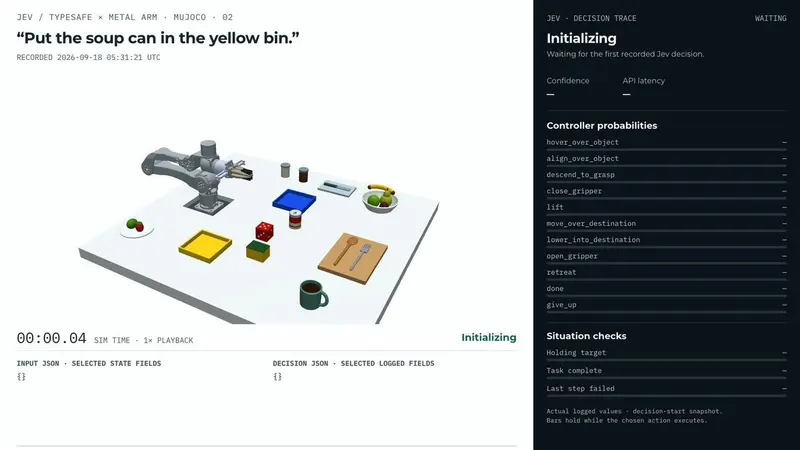
A video demo drives a MakerMods robot arm in MuJoCo using Jev: the model receives the scene as JSON state and picks the next bounded action, such as hover, descend, grasp, lift, or place, as a typed choice with a confidence score, completing a task in 9 decisions at about 150 milliseconds each.
Interactive demo that evaluates smart home requests with speculative questions and falls back to an LLM when Jev is uncertain.
Nothing matches those filters
Clear a filter to widen the search, or send us the thing you were looking for.
The loop is: read the sensors, turn them into a compact state, ask the model for the next bounded action, and run it through a safety layer. lykycy123/RoboJEV uses two stages: Jev picks an intent, then picks motion and a gripper command. TarunTomar122/jev-askable-arm has Jev pick one of about 30 hardcoded primitives per step. The safety layer should reject any action outside set bounds.
Smart homes use choice for intent and score or noul for conditions. Laya for Home Assistant by allenporter scores registered intents and exposed entities with Laya in one forward pass. luxus/ha-conversation-jev lets Jev handle simple light actions and hands anything else to Grok, gated by confidence. Keep the list of devices and intents the model can see short, since it can only pick among what it is shown.
Loop rate is the limit. The drone entry runs Jev in its control loop at 2.5 Hz, which suits slow, high-level choices and not low-level motor control. Keep fast control in ordinary code and let the decision model pick goals or targets. Several entries also run the model less often than the control loop, passing it a summary of the state. Test in simulation first, and add a hard stop that does not depend on the model.
In simulation, yes. Entries here have Jev picking the next bounded action for a Franka Panda arm in MuJoCo and ManiSkill and for a drone. Real hardware needs a safety layer outside the model, and few entries show it.
Yes. AboveColin/HA-Jev and allenporter/home-assistant-typesafe connect it to Home Assistant, and luxus/ha-conversation-jev uses it to classify spoken commands. Laya for Home Assistant runs fully local.


