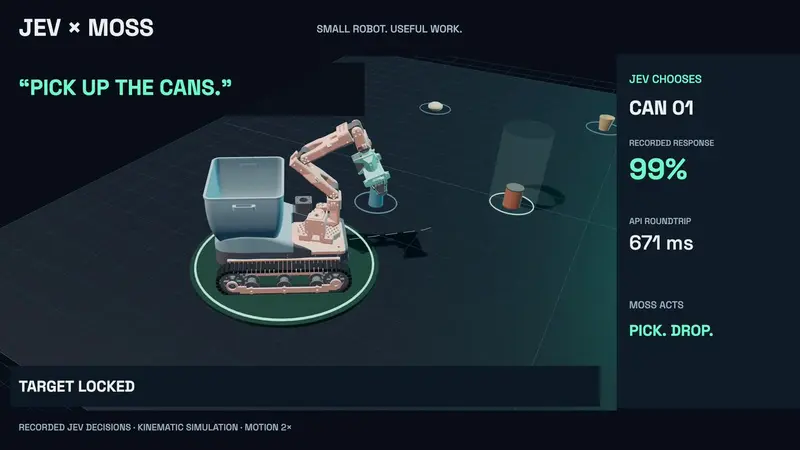
 Play the video in the post below
Post on X
- Views
- 36,909
- Likes
- 112
- Reposts
- 9
Read from X on . Counts change daily.
MOSS is a litter-picking robot arm. The page replays recorded runs in a MuJoCo physics simulation instead of calling Jev live: it is marked “replay only,” with recorded Jev decisions and no API calls during playback. A viewer can drag to orbit and scroll to zoom around the scene.
The page has two sets of demos. The original v0.1 demos, such as “cans only” and “bottles only,” replay recorded Jev target choices with scripted motion. That is what metrox_eth’s post shows: changing the instruction from “pick up the cans” to “pick up the bottles” changes the target Jev picks. The newer v0.2 physics replays hand Jev more of the loop. At each step it picks the arm’s next action from a fixed list (approach, align, close, lift, carry, release, retry, home and a few others), and the recording keeps the probability Jev gave each option.