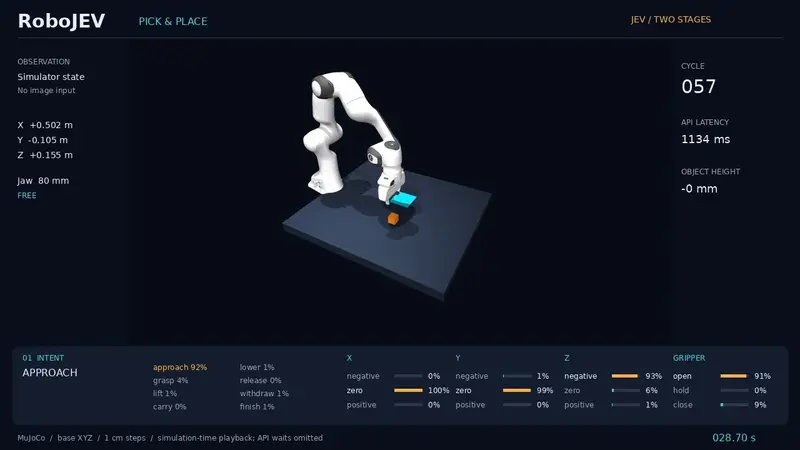
lykycy123/RoboJEV on GitHub
- Stars
- 42
- Forks
- 2
- Language
- Python
- License
- Apache-2.0
- Last push
- 23 Sep 2026
Read from GitHub on . Counts change daily.
How it uses Jev
model_config = ConfigDict(extra="forbid")
provider: Literal["typesafe"] = "typesafe"
model: str = Field(default="jev-1.13.0", min_length=1, max_length=120)
api_url: str = "https://api.typesafe.ai/v1/systemone"
api_timeout_s: float = Field(default=25, gt=0, le=300)
api_retries: int = Field(default=2, ge=0, le=2, strict=True)

@model_validator(mode="after")
def valid_url(self):
    url = urlsplit(self.api_url)
    if url.scheme != "https" or not url.hostname or url.username or url.password or url.query or url.fragment:
        raise ValueError("Use an HTTPS API URL without credentials, query or fragment")
    return self
View in src/robojev_ui/models.py
PrimitivesChoice