 Play the video in the post below
Post on X
- Views
- 8,727
- Likes
- 149
- Reposts
- 14
Read from X on . Counts change daily.
Use casesReal-time control
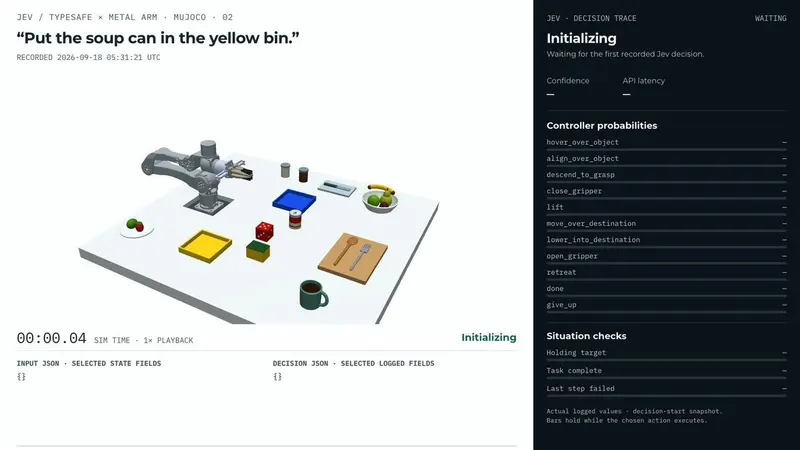
A video demo drives a MakerMods robot arm in MuJoCo using Jev: the model receives the scene as JSON state and picks the next bounded action, such as hover, descend, grasp, lift, or place, as a typed choice with a confidence score, completing a task in 9 decisions at about 150 milliseconds each.
Play the video in the post belowRead from X on . Counts change daily.
Browser Use's fast browser agent where Jev picks the operation and the DOM element in a single request; a small LLM is only invoked to write text when typing is required. Demoed on a Google Flights search.
19k starsFlight search 7.1 s
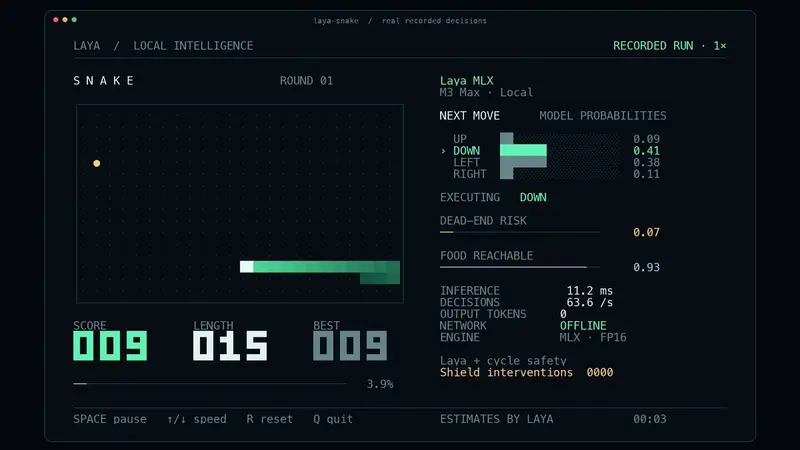
An independent MLX port of Laya for Apple Silicon, 13.4ms median for a short English decision and 7.4ms on the multilingual checkpoint, with a Snake demo that plays at up to 75 moves per second under 1GB of memory.
 mizorewwwOpenLaya-MLX on github.com
6.1k starsShort decision 13.4 ms P50Snake demo 75.4 moves/s
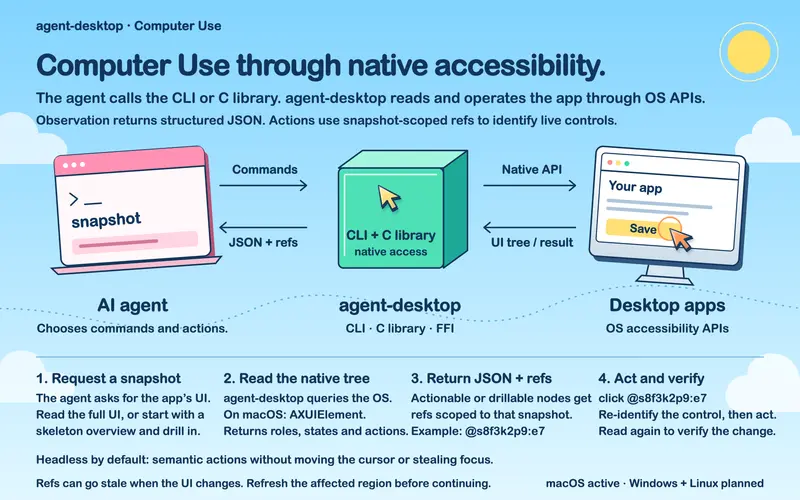
Rust desktop automation that reads apps through the OS accessibility tree instead of pixels. Its jev-desktop skill takes a plain-language goal and has Jev pick one operation and one target element per turn, so the 150-element tree never enters the agent's context.
1.6k starsToken reduction 78-96%
Core ML ports of all three Laya checkpoints for Apple Silicon, reaching 4.98ms P50 on the Neural Engine for a short multilingual decision, with a Snake demo sustaining about 50 decisions per second.
 mizorewwwOpenLaya-CoreML on github.com
1.4k starsShort decision 4.98 ms P50Snake demo 49-50 dec/s
macOS computer-use loop that OCRs the screen, classifies the next action with Jev, then clicks. Author reports roughly $0.0002 per step.
 Aaron Levin (awlevin)Opentypesafe-computer-use on github.com
935 starsCost/decision $0.0002, 155xLatency 0.13-0.38s
A Minecraft agent that pairs an Astra planner with Jev as the real-time controller, with native run recording, tested routes and run verification.
536 starsFastest run 8m 43s, -40%Decisions used 131 Jev calls


