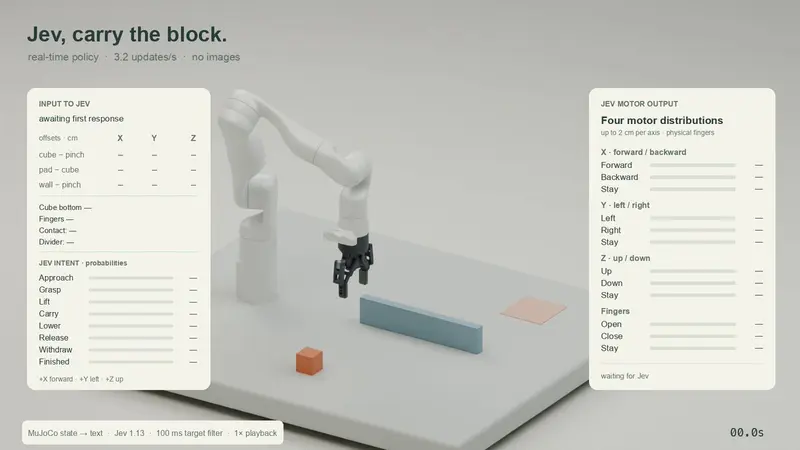
 Play the video in the post below
Post on X
- Views
- 44,986
- Likes
- 628
- Reposts
- 52
Read from X on . Counts change daily.
Dmytro Hrybov tested Jev as a real-time control policy for a robot arm in the MuJoCo physics simulator, shown in a video in the post. Jev does not accept images, so the scene reaches it as text: simplified geometry and contacts.
Jev struggled at first, so he split each update into two Jev calls: one to decide what to do next, and a second to decide how to move the arm and gripper. The post does not share code or say which question types the two calls use.
PrimitivesChoice
Use casesReal-time control